FLAIR · project
CDGS: Compositional Diffusion with Guided Search
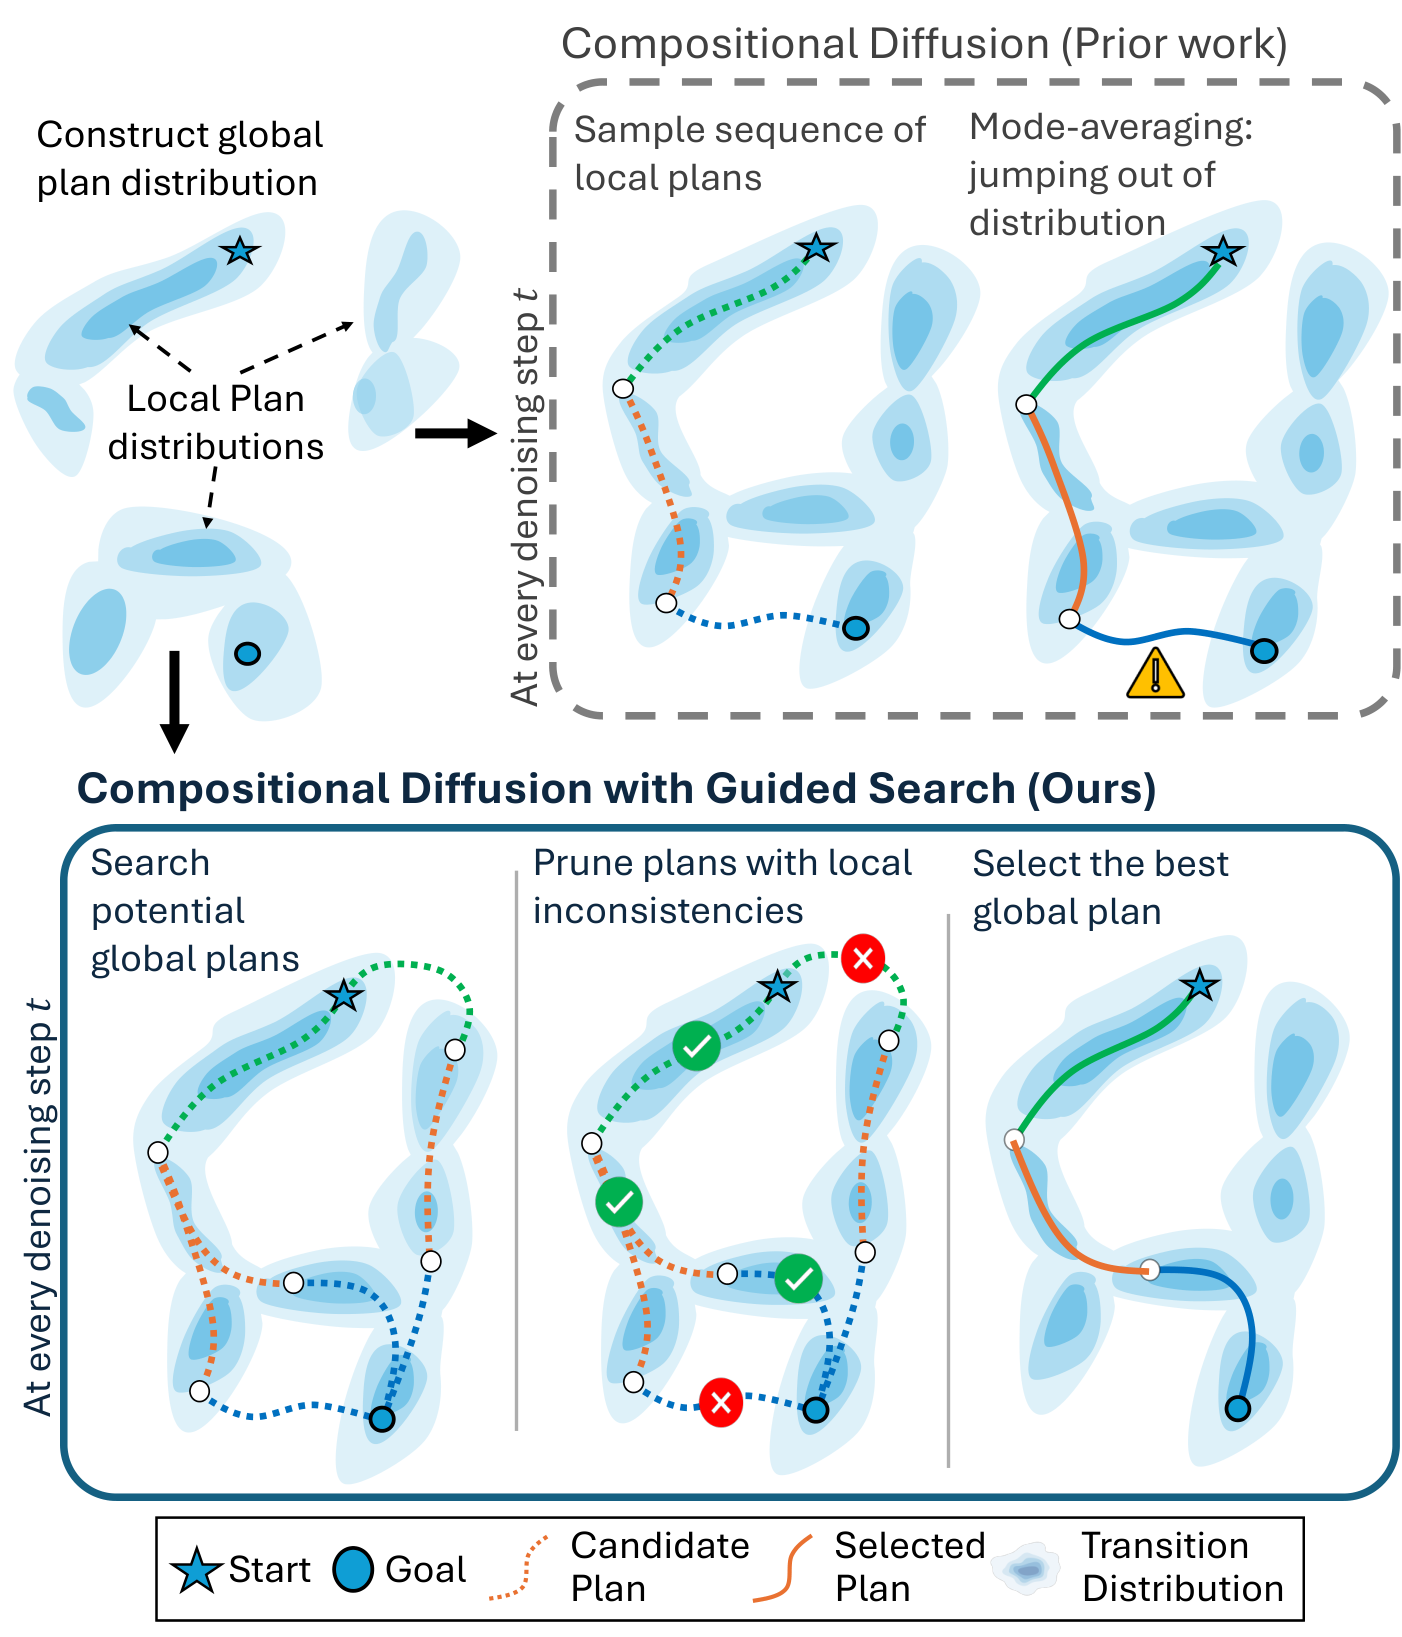
Local generative models can represent short behaviors or small pieces of a scene, but composing them into a long plan is difficult when each piece has several plausible outcomes. Averaging incompatible choices can produce a result that is neither feasible locally nor consistent globally. CDGS introduces search into diffusion sampling to resolve this ambiguity.
Search inside the denoising process
A population of candidates explores different combinations of local modes. Likelihood-based filtering removes incompatible candidates, while iterative resampling exchanges information between overlapping segments. These operations coordinate local decisions as denoising proceeds, helping the composition settle on a coherent global solution.
Planning and generation
The paper evaluates long-horizon robot manipulation and extends the same compositional idea to panoramic images and long videos. These experiments test whether local models can be reused to produce larger, consistent outputs. The project site contains demonstrations, while separate code repositories support the image/video and OGBench experiments.
Watch demonstrations on the CDGS project site.
Publication
Compositional Diffusion with Guided Search for Long-Horizon Planning
Utkarsh A. Mishra, David He, Yongxin Chen, and Danfei Xu
ICLR 2026